Geometry & SLAM
OpenGV 2.0: Motion prior-assisted calibration and SLAM with vehicle-mounted surround-view systems
arXiv:2503.03230 · Preprint · 2025
RESEARCH SUMMARY
OpenGV 2.0 uses vehicle motion priors to improve surround-view camera calibration, relative pose estimation and SLAM, including configurations with little overlap between cameras.
Read the supporting paper ↗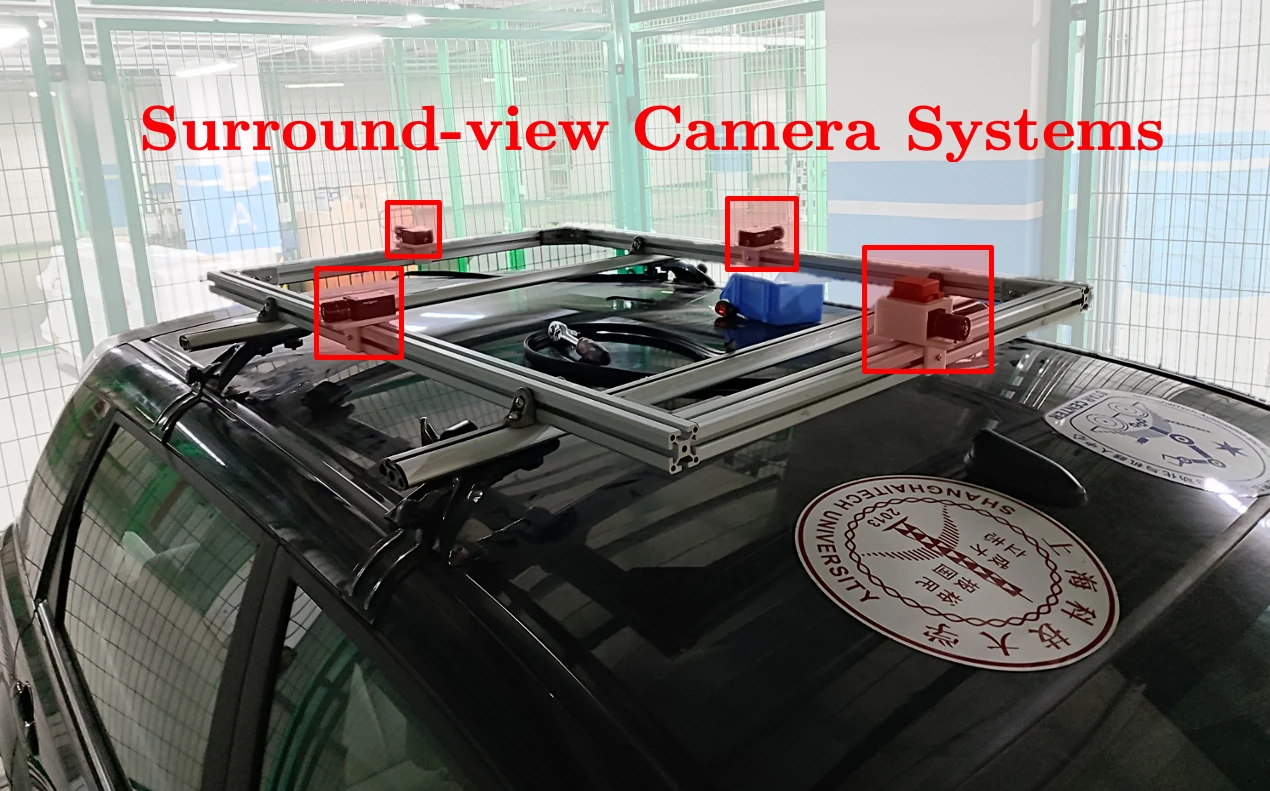
THE RESEARCH QUESTION
How can vehicle motion help a surround-view SLAM system?
Cameras mounted around a vehicle observe different parts of the environment. Limited overlap and constrained vehicle motion can make calibration and motion estimation poorly observable. The method uses those motion constraints explicitly instead of ignoring them. [Paper]
How the method works
- Two-view geometry supports online extrinsic calibration and relative-pose initialization for the multi-camera rig.
- A continuous-time spline backend incorporates non-holonomic motion priors to refine the trajectory and scene estimates.
RESEARCH INTERPRETATION
What this contribution means
The paper connects calibration, initialization and trajectory refinement around a common vehicle-motion model. Its evaluations and ablations examine how these priors help under the geometry of vehicle-mounted surround-view systems.
This section explains the contribution in context. For experimental protocols, numerical results and comparisons, consult the original paper.
Scope and limitations
The benefits depend on how well the vehicle's actual motion matches the assumed constraints. The research record should be consulted for data and release details; a paper title alone does not establish software availability. [Paper]
Questions about this research
Is OpenGV 2.0 designed only for overlapping stereo cameras?
No. It addresses vehicle-mounted surround-view systems, where overlap between cameras may be limited.
Sources, paper & code
Primary research sources support the summary above. Project resources provide demonstrations or implementations; Google Scholar is a bibliographic index.
- Primary sourcearXiv — paper record and versions ↗arxiv.org
- Primary sourceFull paper — PDF ↗arxiv.org
- Metadata indexGoogle Scholar — bibliographic listing ↗scholar.google.com